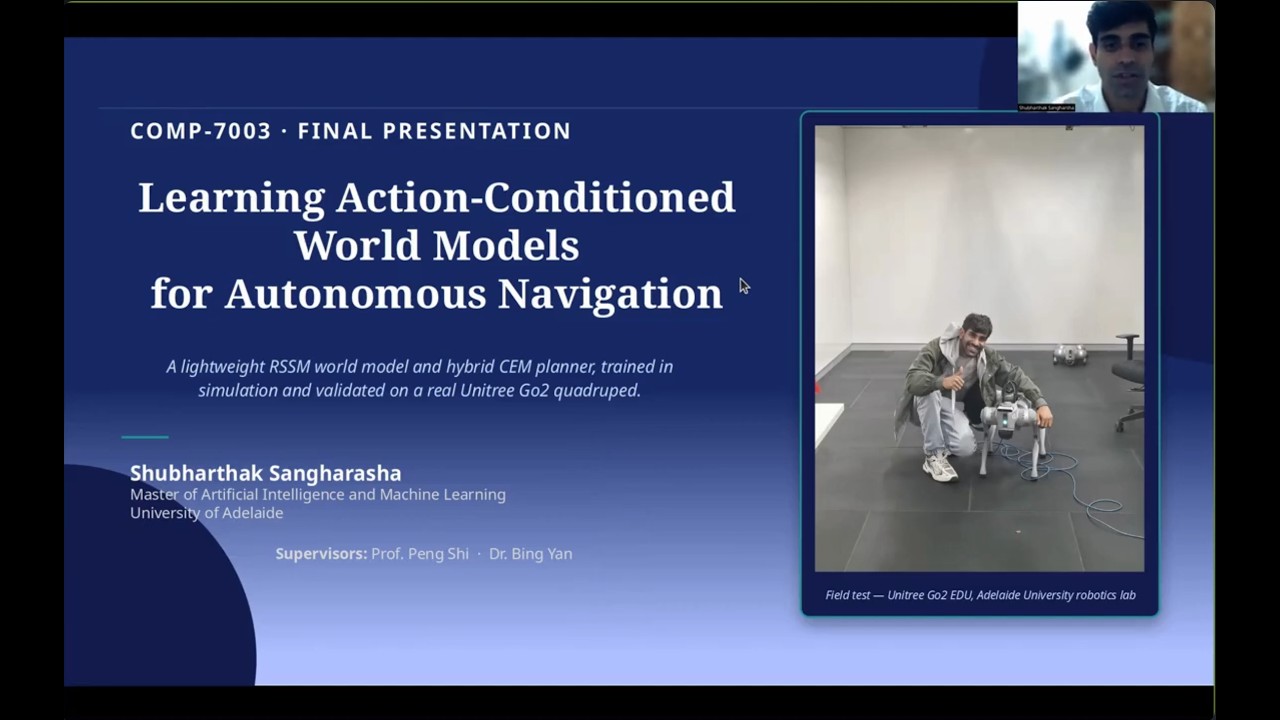
World Models for Robot Navigation on Unitree Go2
Master's capstone. An RSSM world model trained on 617K simulated and 10.8K real Go2 transitions, with a CEM planner and a proximity gate for safe navigation without a map.
Projects
Research, experiments and small tools I've built outside client work. The code for each one is on GitHub.
Master's capstone. An RSSM world model trained on 617K simulated and 10.8K real Go2 transitions, with a CEM planner and a proximity gate for safe navigation without a map.

Desktop assistant built with Electron, React and Python. It takes voice commands, can see the screen, and runs tasks on the computer through LangChain tools.
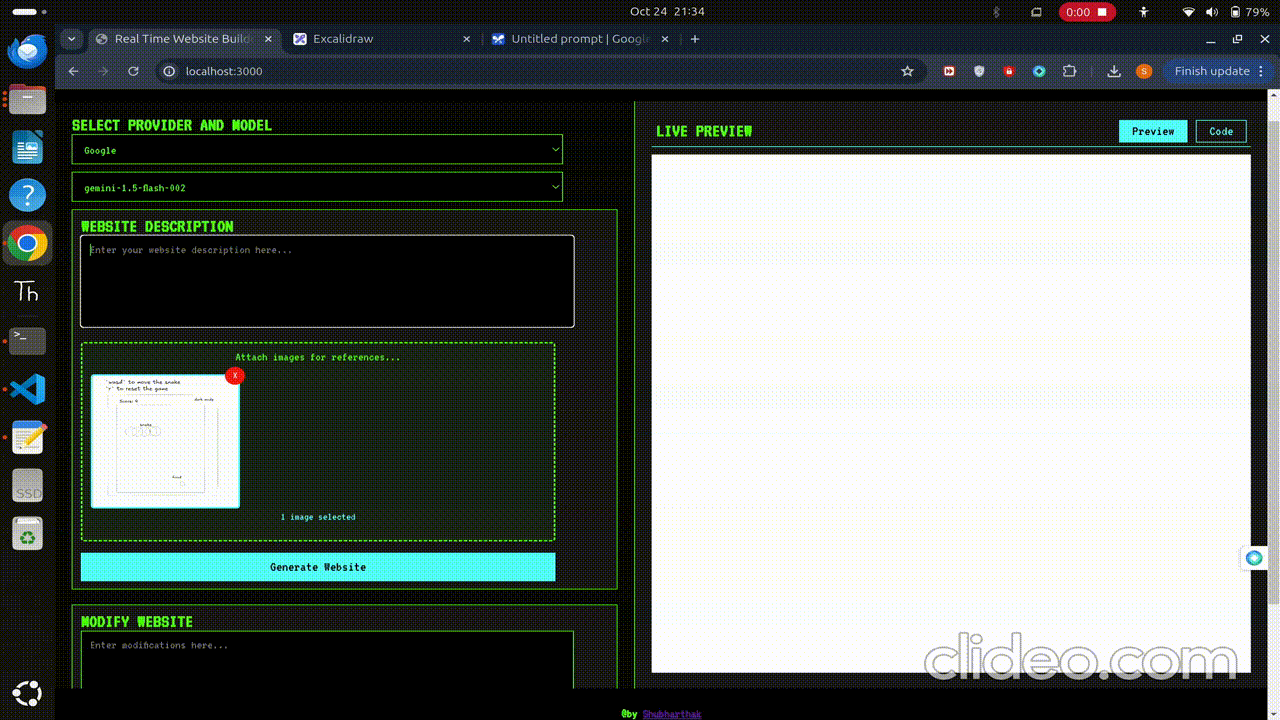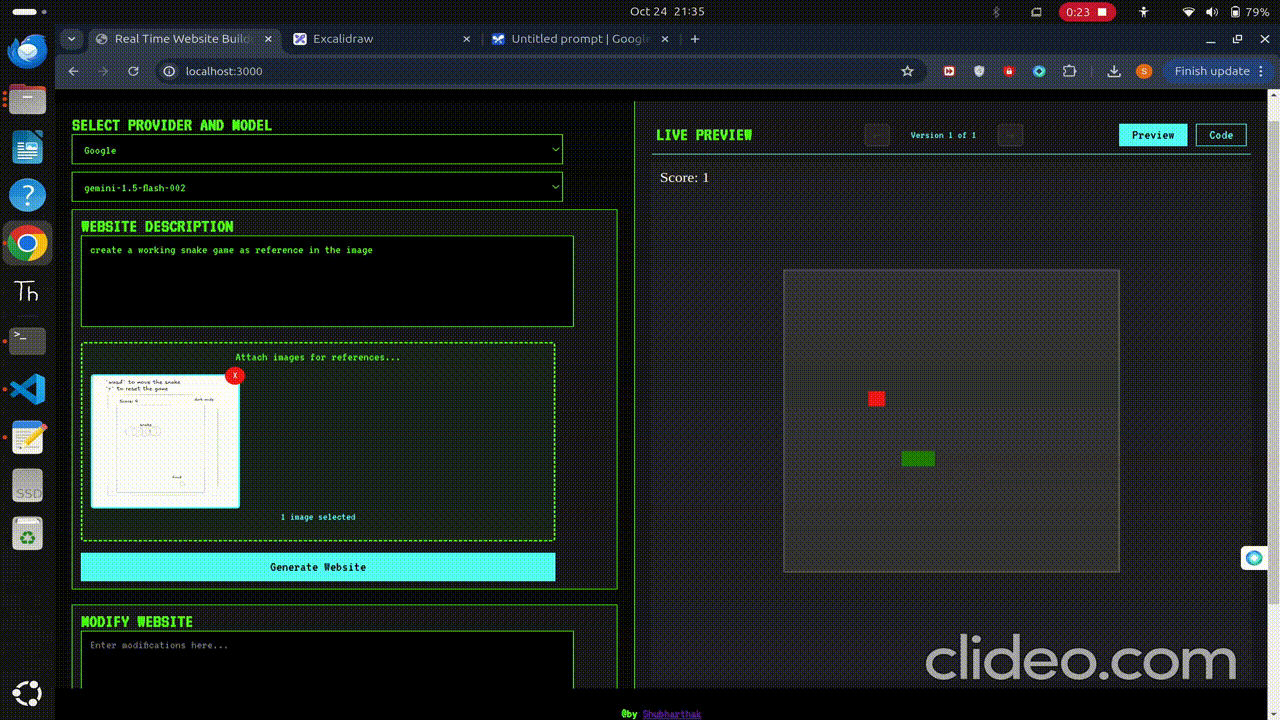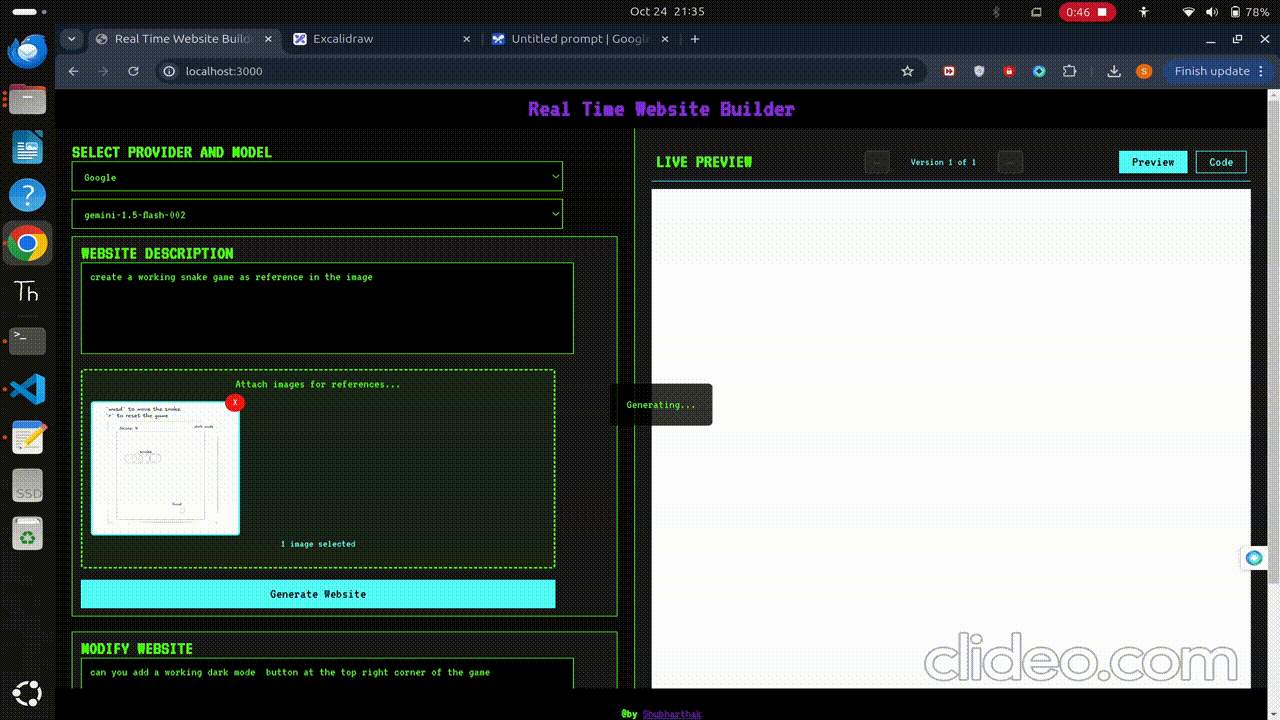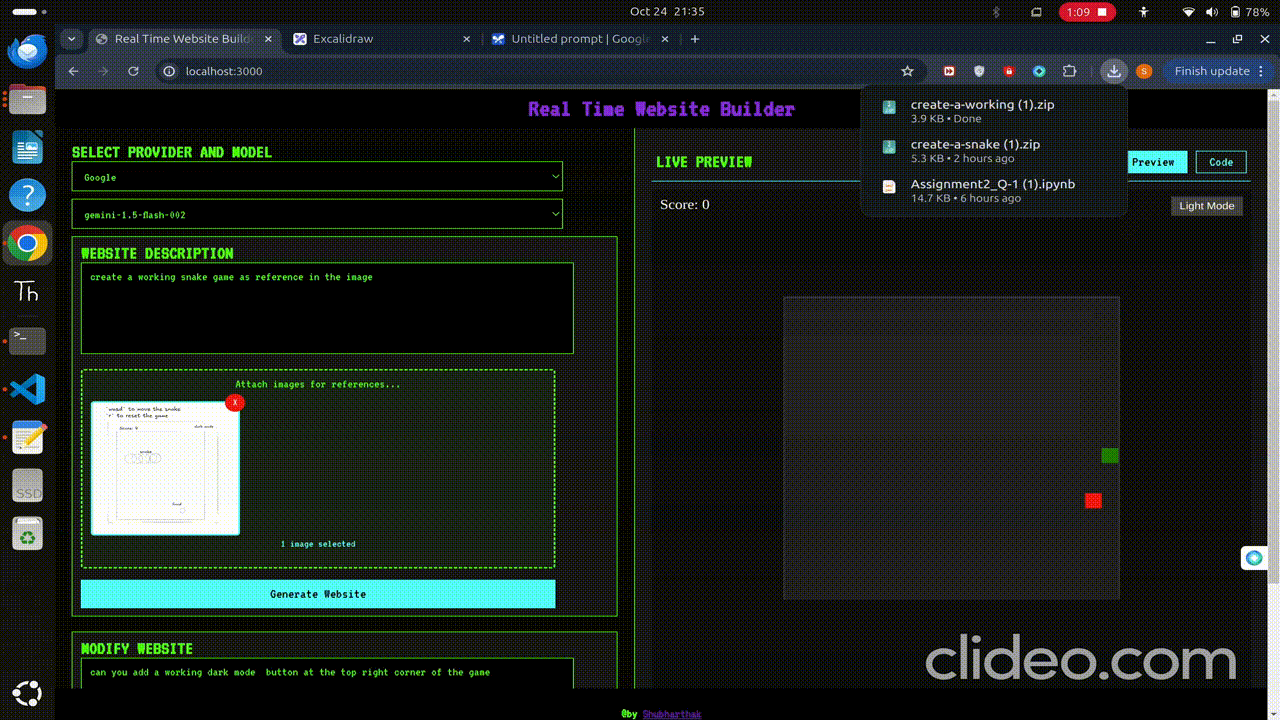
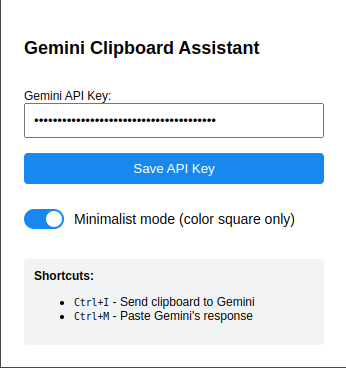
Chrome extension that uses the Gemini API to read and summarise pages, work with clipboard content, and help with browser tasks.
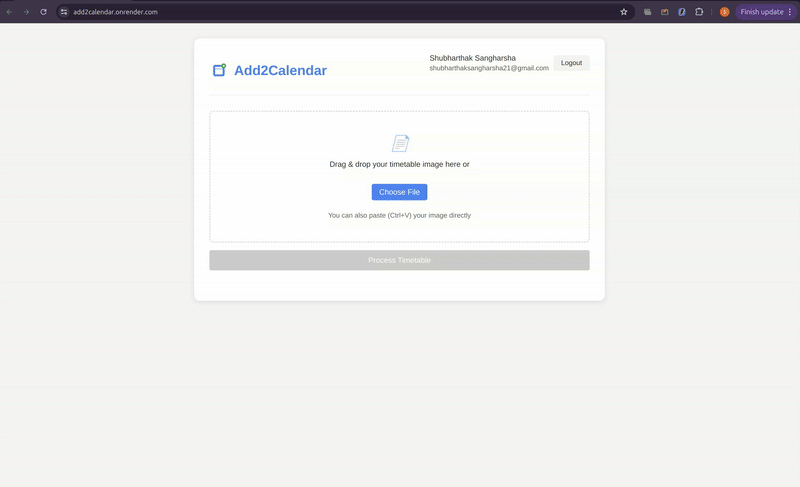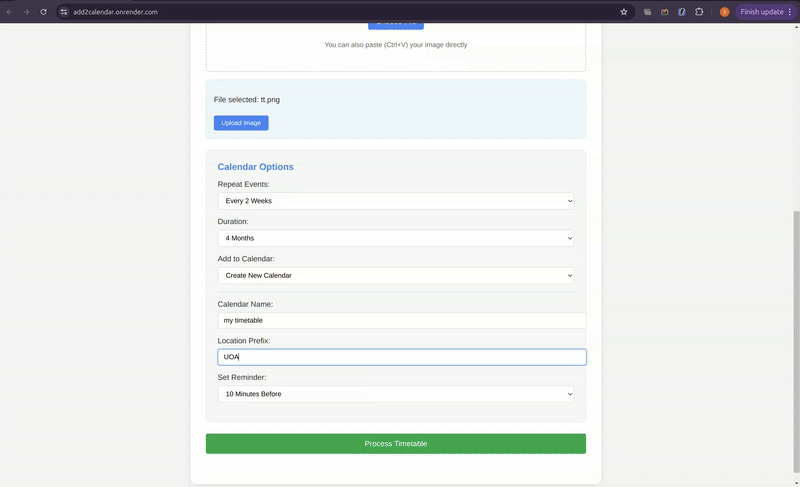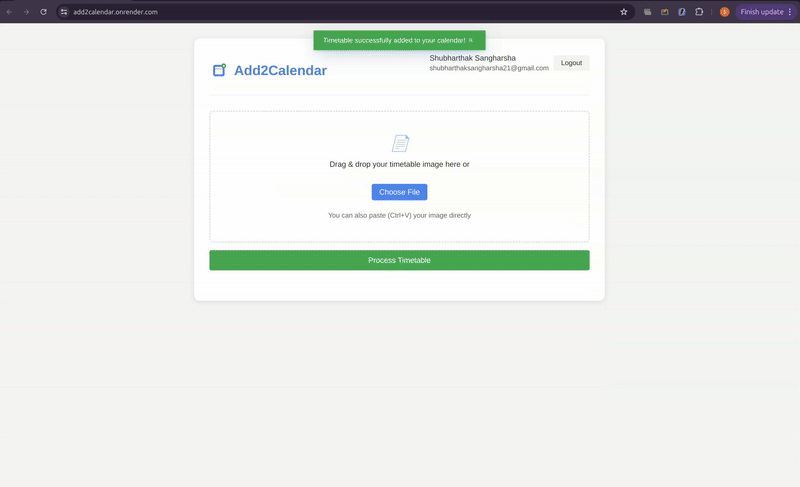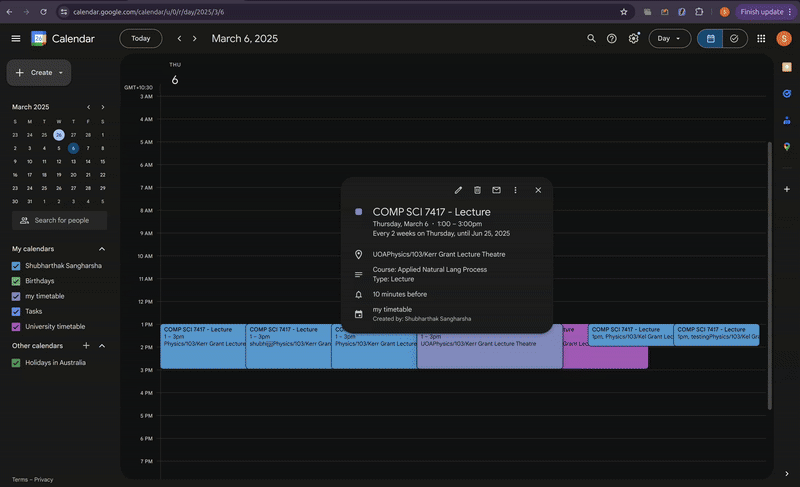
Turns a plain-English event description into an .ics file and one-click Google Calendar or Outlook links.
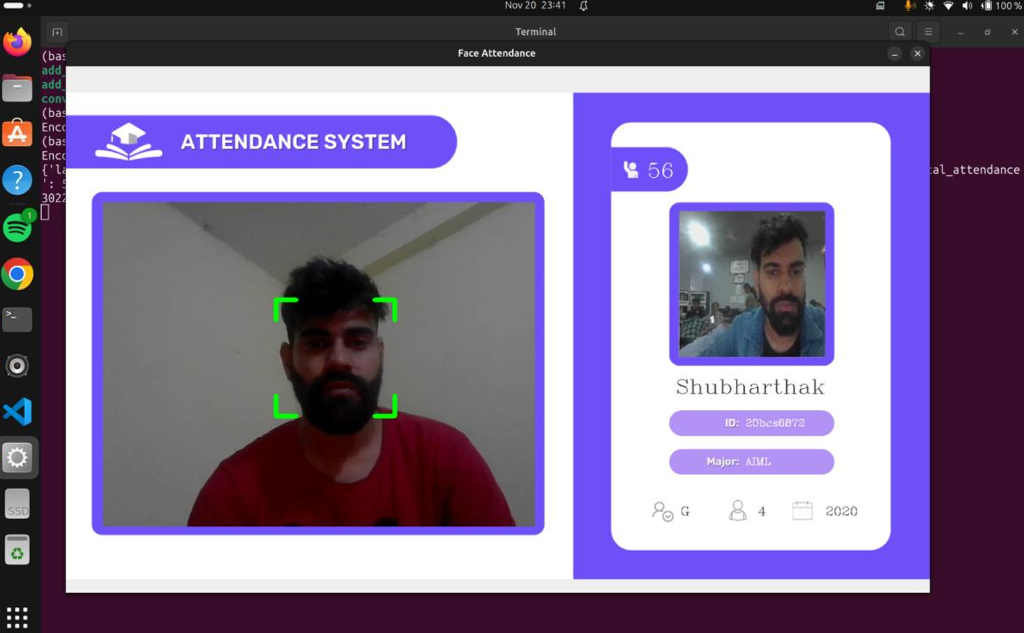
Marks attendance from a camera feed by matching faces against stored embeddings using dlib and OpenCV, then logs each record.
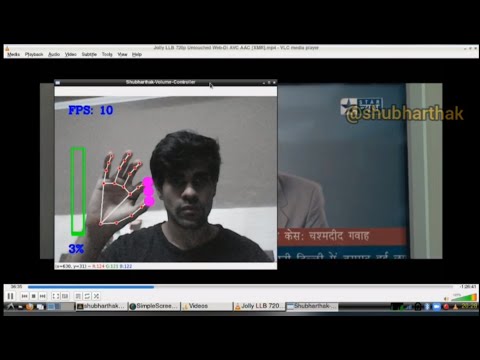
Controls system volume with hand gestures, using MediaPipe hand landmarks and OpenCV.

A TensorFlow/Keras classifier using transfer learning to detect whether people in a video feed are wearing masks, with a Flask front end.

A WiFi-controlled car built on an ESP8266, written in C++ and driven from the Blynk app.